In one sentence: subtract the previous frame from this one, keep the pixels that changed by more than a threshold, join them into regions — and you have the plainest useful machine there is: one that never blinks.
← 03 · Handbook · Site: /learn, chapter 6 · /story · Run: node examples/04-motion.mjs
1. Why motion comes first
The idea behind this whole site began in city operations centres: a wall of hundreds of camera feeds, a few operators, and the plain fact that people blink, doze, text and take breaks. The first useful thing a machine can do there is not to understand a scene, but to not miss that something changed — and tap a human on the shoulder: this screen, now. No model, no names, no faces. Only "these pixels changed". The /story room runs exactly this over six live cameras.
2. Three steps
// public/js/cv/ops.js
const changed = ops.diffMask(previousGray, currentGray, delta)  // 1 where |Δ brightness| ≥ delta
const joined  = ops.dilate(changed, width, height)              // grow each spot by one pixel
const regions = ops.blobs(joined, width, height, minArea) // connected regions → boxes- Difference. For every pixel,
|now − before|. If it is at leastdelta, mark it 1. - Dilate. Grow every marked pixel into its 3×3 neighbourhood, so a car's broken outline becomes one shape.
- Connected regions. Flood-fill each group of touching marked pixels; record its bounding box and area; drop groups smaller than
minArea(noise).
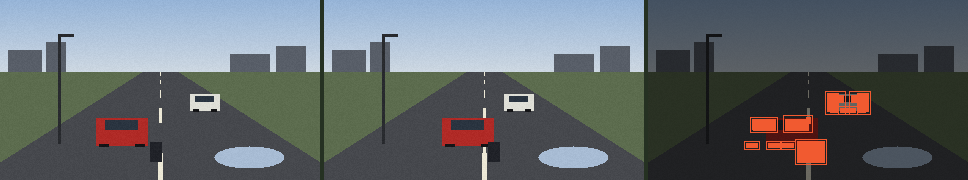
The answer key says three vehicles moved:
car        x 96 → 118
car        x 190 → 180
motorcycle x 150 → 164
What the machine reports (delta = 18):
  #   box (x, y, w × h)      area
  1   (149, 141, 28 × 22)    616
  2   (137, 117, 26 × 14)    308
  3   (104, 119, 24 × 12)    287
  4   (203, 93, 18 × 20)     284
  5   (179, 93, 17 × 20)     276
  6   (192, 108, 16 × 5)      80
  7   (98, 143, 12 × 5)       60
  8   (120, 143, 12 × 5)      60
  9   (134, 143, 12 × 5)      60
Nine regions for three vehicles. A uniformly coloured car moving sideways changes only its leading and trailing edges — where it arrived and where it left; the middle of its body was red before and is still red now. Its wheels make their own little slivers. Differencing sees change, not objects. Counting objects from motion needs another step (merging nearby regions, tracking them over time) — or a detector (chapter 06).
3. The threshold is a bet against noise
Every real camera has grain: even a perfectly still scene changes by a few brightness levels between frames. So delta decides what counts as "real" change. The example compares two frames where nothing moved (only the noise is different) against two where the cars did:
delta  4:  nothing moved →  31.7% px changed,   1 region   ·   cars moved →  34.7% px,   1 region
delta  8:  nothing moved →   0.8% px changed,  60 regions  ·   cars moved →   4.3% px,  59 regions
delta 18:  nothing moved →   0.0% px changed,   0 regions  ·   cars moved →   2.5% px,   9 regions
delta 40:  nothing moved →   0.0% px changed,   0 regions  ·   cars moved →   1.2% px,   8 regions
delta 90: nothing moved → 0.0% px changed, 0 regions · cars moved → 0.7% px, 5 regions- delta 4: grain flips a third of all pixels; they fuse into one frame-sized "region". Useless.
- delta 8: 60 false regions from noise alone — an alarm that never stops.
- delta 18–40: silence when nothing moves, a clear signal when something does. The sweet spot.
- delta 90: too strict — real things go missing. Which ones? The example can say exactly:
delta 18  motorcycle 28×22 · red car 26×14 · red car 24×12 · white car 18×20 · white car 17×20 · white car 16×5 · red car 12×5 · red car 12×5 · red car 12×5
delta 40  motorcycle 28×22 · white car 18×20 · white car 17×20 · white car 16×5 · red car 12×5 · red car 12×5 · red car 12×5 · red car 5×7
delta 90  white car 18×19 · white car 17×19 · motorcycle 6×17 · white car 16×4 · red car 5×7
At 18 the red car shows up as its dark windscreen (26×14, 24×12) and three wheel slivers (12×5). At 40 the windscreen is gone; at 90 one 5×7 sliver remains, and the motorcycle has shrunk to a strip.
The red car fades first, and even at 18 it is seen only through its windscreen and wheels: its body is almost exactly as bright as the asphalt it moves over (chapter 02's lesson again — 81.6 against 72.0). The white car, 150 levels brighter than the road, survives every threshold. Motion detection is easiest for whatever contrasts most with the background — which is not the same as whatever matters most.
The site's motion lens uses 22; the /learn slider lets you move it from 4 to 80 on a live camera. Like every number in classical vision, it is chosen, not learned — and not perfect.
4. What breaks frame differencing in the real world
| Situation | What the machine reports | Why |
|---|---|---|
| Wind in trees, rain, flags | constant "motion" | they really are moving pixels |
| Camera shake on a pole | the whole frame changes | every pixel shifted |
| Clouds passing, lights switching on | large changes, no object | brightness changed everywhere |
| Video compression (H.264) | blocky flickers | keyframes and quantisation change pixel values |
| A traffic jam | "nothing moving" | stationary cars do not change |
| A fogged or dead lens | "nothing moving" | the picture does not change — indistinguishable from an empty road |
The last two are why this project never publishes a negative claim from motion. A positive finding — "something changed here" — is a claim about the image. A negative one — "the road is clear" — would be a claim about the world, and a frozen or fogged camera is pixel-identical to an empty road. FloodDash found exactly such a camera on 28 September 2026; its traffic detector had called the road "stopped".
5. From differencing to the real thing
Production systems improve each step:
- Background models — instead of the previous frame, compare against a slowly updated average of many frames (a "running average" or a mixture of Gaussians per pixel; Stauffer & Grimson, 1999). Waving trees become part of the background.
- Optical flow — estimate where each pixel moved, not just whether it changed (Lucas–Kanade, 1981; Horn–Schunck, 1981). Gives direction and speed.
- Tracking — link detections across frames into identities-over-time (the "same car" in frame 1 and frame 40), e.g. with a Kalman filter. This is where privacy questions sharpen: tracking an object is one step from tracking a person.
Try it yourself · ลองทำเอง
เป้าหมาย · Goal: ทำให้การเคลื่อนไหวปรากฏด้วยการลบภาพสองภาพ แล้วหาจุดที่เสียงรบกวนเริ่มชนะสัญญาณ / Make motion appear by subtracting two frames — then find where noise starts beating the signal.
ขั้นตอน · Steps
- เปิด /learn บท 6 วางกล้องนิ่ง ๆ แล้วดูว่าไม่มีอะไรถูกทำเครื่องหมาย — Open /learn chapter 6, hold the camera still, and watch nothing get marked.
- โบกมือขึ้นมา แล้วดูบริเวณมือถูกทำเครื่องหมายตาม — Wave a hand and watch the marked region follow it.
- ค่อย ๆ ยก "ต้องเปลี่ยนอย่างน้อย" ขึ้นเรื่อย ๆ จนมือหายไป แล้วจดค่าไว้ — Raise Minimum change until the hand stops being detected, and note the value.
- ทำซ้ำในที่มืด แล้วเทียบกับที่สว่าง — Repeat in a dark spot and compare with a bright one.
ควรเห็น · You should see
- ค่าต่ำ ความสั่นเล็ก ๆ ของเซนเซอร์ถูกนับเป็นการเคลื่อนไหว — At a low value the sensor's own jitter counts as motion.
- ค่ากลาง เห็นเฉพาะมือ ส่วนค่าสูงไม่เห็นอะไรเลย — In the middle only the hand shows; higher and nothing does.
ถ้าไม่เห็น · If you do not — ถ้าไม่มีอะไรขึ้นเลย ค่าอาจสูงเกินไป ให้เลื่อนลง หรือเพิ่มแสงให้ฉาก — If nothing appears the value is probably too high: slide it down, or light the scene.
Check yourself
1. A white car drives across a white wall. What does frame differencing see?
Very little — only the parts of the car whose brightness differs from the wall (windows, wheels, shadow). Differencing measures change in brightness, not the presence of an object.
2. Why does the /story wall flag only screens whose changed share exceeds 0.4%?
The same reason as delta: below a small share, change is likely noise or compression flicker. ATTENTION_MIN_CHANGE = 0.004 in public/js/story/wall.js is a second threshold, on the area rather than the pixel.
3. A camera shows no motion for an hour. Name three different situations that would produce this.
An empty road; a total traffic jam; a frozen, fogged or disconnected camera. The pixels cannot tell them apart — which is why "no motion" is never published as "road clear".
สรุปภาษาไทย
เครื่องจับการเคลื่อนไหวคือเครื่องที่ง่ายที่สุดแต่มีประโยชน์ที่สุด: เอาภาพนี้ลบภาพก่อนหน้า ตรงไหนเปลี่ยนเกินเกณฑ์ให้เป็น 1 ขยายจุดให้ต่อกัน แล้วรวมเป็นกลุ่ม ไม่ต้องมีโมเดล ไม่ต้องรู้ว่าใคร แค่รู้ว่า "ตรงนี้เปลี่ยน" นี่คือสิ่งที่ห้อง /story ใช้เฝ้ากล้องหกตัวพร้อมกัน เหมือนตาที่ไม่กะพริบในศูนย์ควบคุม
รถสามคันที่ขยับ เครื่องเห็นเป็น เก้ากลุ่ม เพราะรถสีเดียวกันทั้งคันเปลี่ยนแค่ขอบหน้าและขอบหลัง การลบภาพจึงเห็น "การเปลี่ยนแปลง" ไม่ใช่ "วัตถุ"
ค่าเกณฑ์ (delta) คือการเดิมพันกับสัญญาณรบกวน: ต่ำไป (4–8) เม็ดเกรนของกล้องกลายเป็น "การเคลื่อนไหว" สูงไป (90) ของจริงหายไป และสิ่งแรกที่หายคือ รถสีแดง เพราะสว่างพอ ๆ กับถนน ส่วนรถสีขาวยังเห็นทุกค่า การจับการเคลื่อนไหวจึงง่ายที่สุดกับสิ่งที่ต่างจากพื้นหลังมากที่สุด ซึ่งไม่ใช่สิ่งเดียวกับสิ่งที่สำคัญที่สุด เว็บไซต์ใช้ค่า 22
ข้อสำคัญที่สุด: "ไม่มีการเคลื่อนไหว" ไม่เคยแปลว่า "ถนนว่าง" เพราะรถติดนิ่ง กล้องค้าง หรือเลนส์ฝ้า ให้ภาพที่ไม่เปลี่ยนเหมือนกันทุกประการ ระบบนี้จึงเผยแพร่เฉพาะข้อค้นพบเชิงบวกเท่านั้น
Next: 05 · Neural networks →